

Hardware setup:
- Advantech AFE-R750 (NVIDIA Jetson Orin AGX)
- 6 Gemini 335lg cameras via GMSL cables
Framework: ROS2 Humble
Software: OrbbecSDK_ROS2 (2.8.6), OrbbecSDK_v2 (2.8.6)
Synchronization setup (ROS2 settings):
- enable_gmsl_trigger: true (for 1 camera)
- gmsl_trigger_fps: 1500 (15Hz) (for 1 camera)
- sync_mode: “secondary_synced” (for all 6 cameras)
Problem:
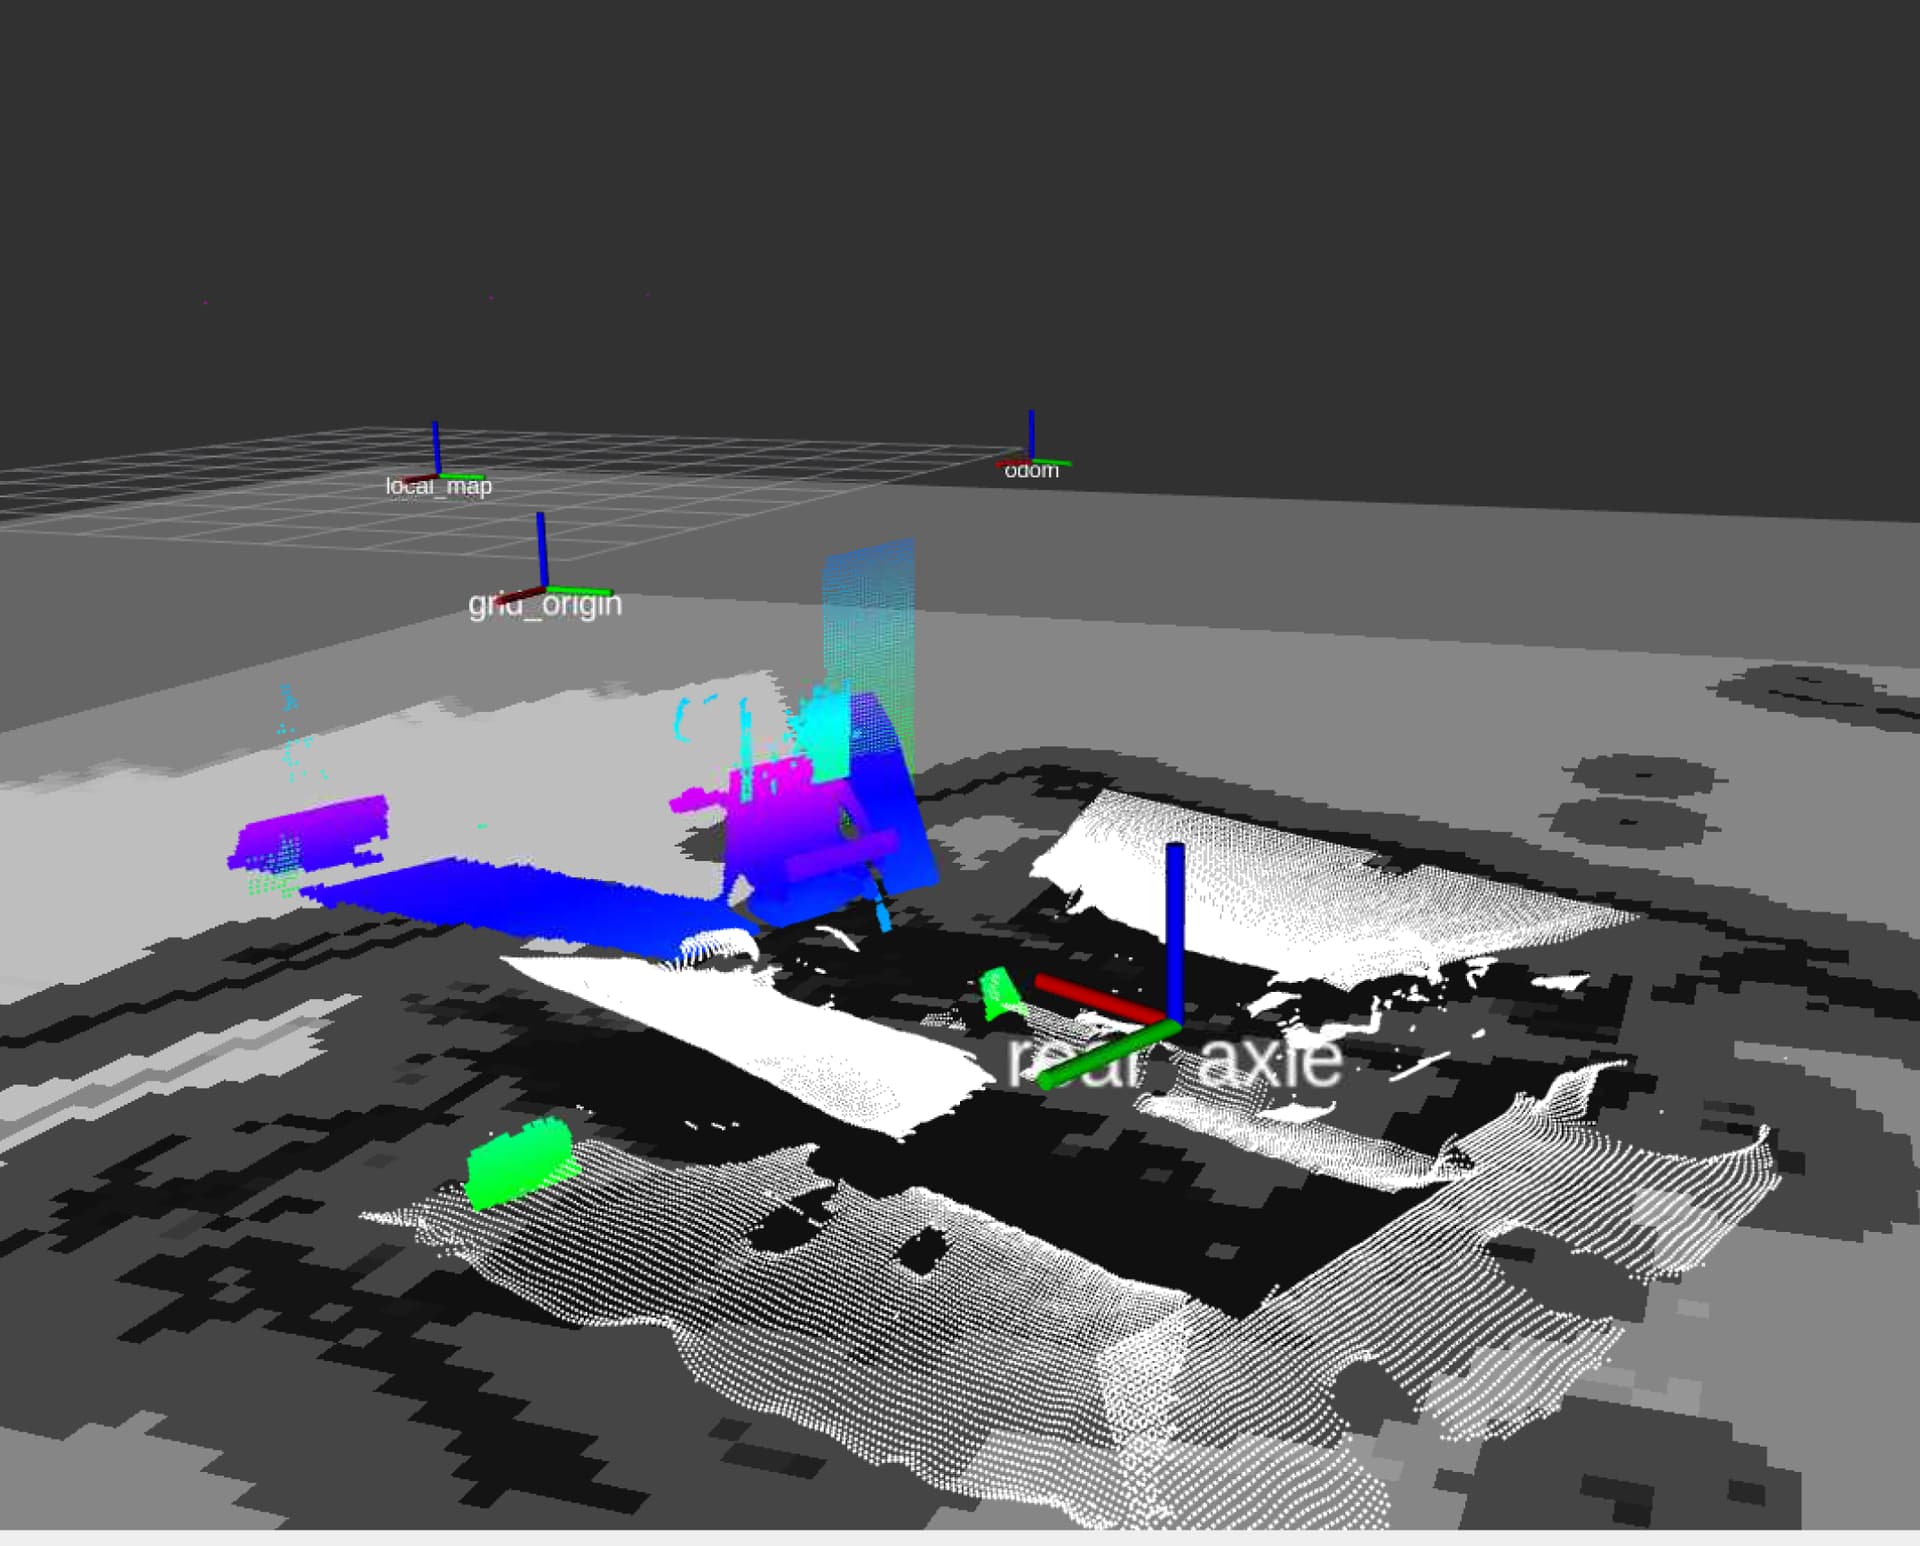
Over time, the point cloud becomes invalid (phantom points start to appear in empty areas). It starts getting worse after ~30 min of the ROS2 wrappers running.
Here is the corrupted point cloud screenshot:
Any help would be appreciated.